a✦ALKAMY EXPERIMENTS EXPERIMENT LAB 01

A SMALL MODEL. A SHARED SPACE.

The Commons.

Twelve little robots. One busy campus.
Can a trained decision model help them share the floor?

✦
Neural policy, running locally9 inputs → 32 neurons → 5 actions · 485 parameters
CONTROLLER
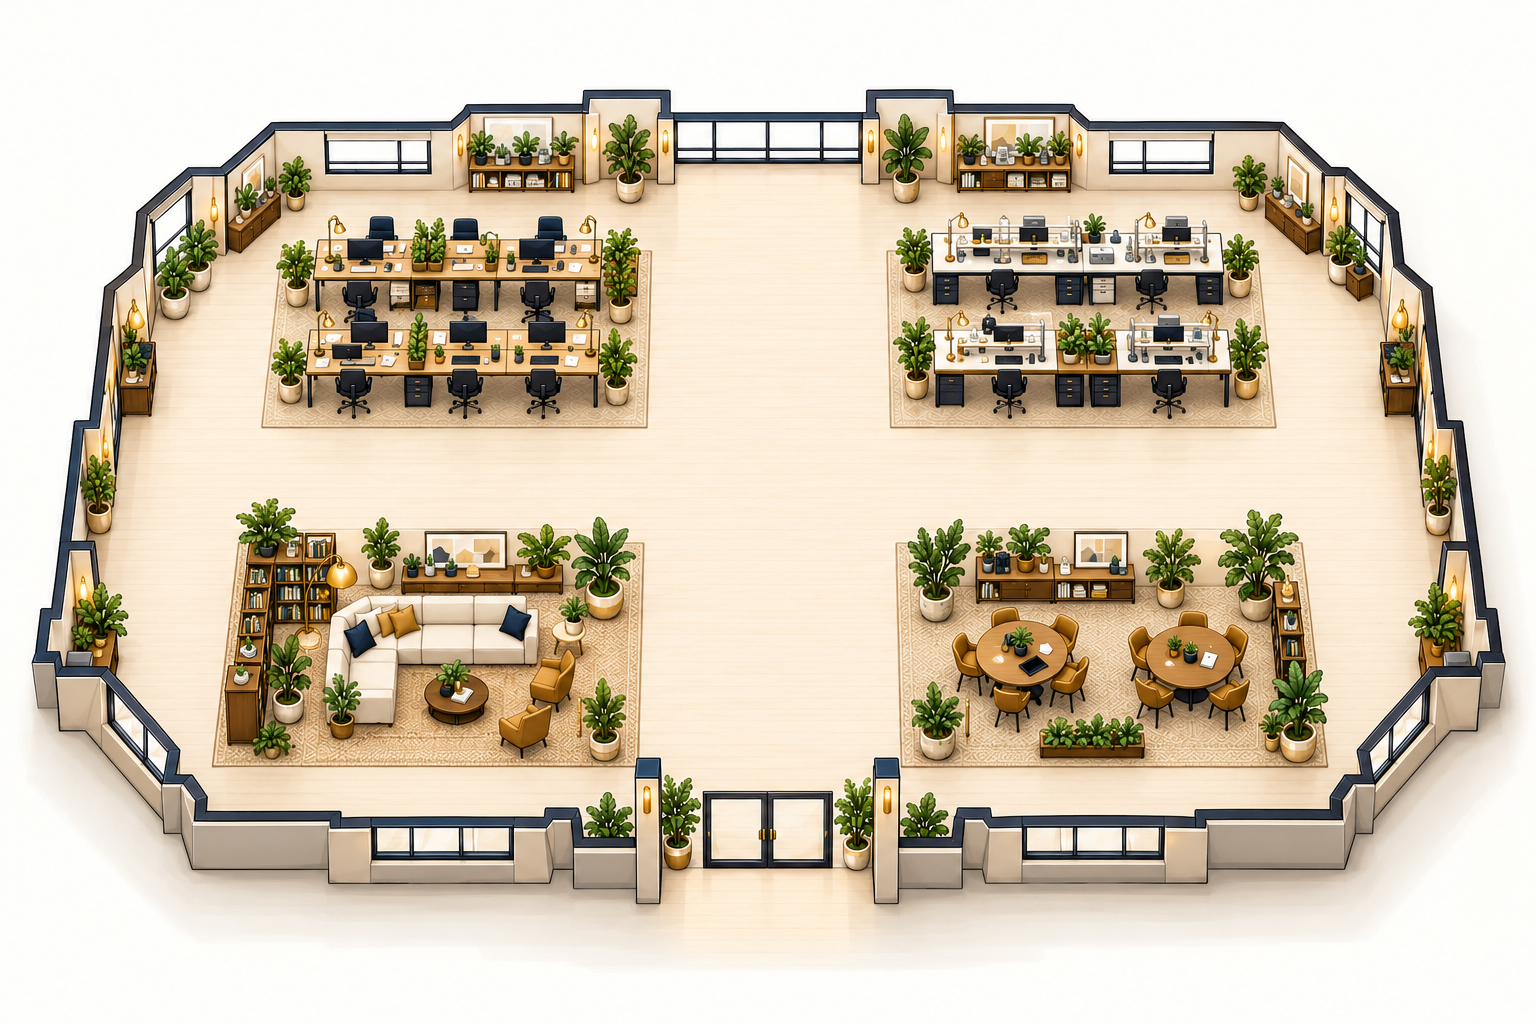
Generated dollhouse campus with four work and lounge areas around open crossing aisles.
THE COMMONS RESEARCH CAMPUS

Swipe across the campus to explore the whole floor.

Collision contacts0Unsafe commands reaching contact
Completed journeys0Arrivals at assigned destinations
Waiting decisions00% of decisions
Guard interventions0Guard inactive

Loading local weights…

TRAINED, THEN TESTED

What did it actually learn?

Follow the requested direction when the next cell is free. Otherwise, wait.
A small first experiment in imitation learning.

01 / TRAINING

Real weights. A tiny task.

A 485-parameter neural network trained for 2,000 epochs on synthetic states using NumPy. The split happened before fitting.

64 train8 dev8 test

8 / 8 held-out states correct

Also checked all 80 discrete states: 80 correct, zero unsafe outputs. This finite check is broader than the tiny test split.
02 / TRAJECTORIES

Safety and progress, together.

20 fresh seeds × 1,200 ticks × 12 robots per controller. Every mode starts from the same positions and per-robot destination sequence.

ControllerContactsJourneysWait %
Loading saved evaluation…
Unsafe commands stop at contact in every mode. Guarded mode blocks them before contact. Counts measure this discrete simulator.

THE SYSTEM AROUND THE MODEL

One learned part.
Every part visible.

The campus artwork sets the scene. Authored geometry supplies the floor, A* plans the route, and the model decides whether to take the next step.

  1. 01
    Imagegen → campus artworkA fresh Alkamy-inspired scene. The network never reads these pixels.
  2. 02
    Grid + planner → requested directionStatic furniture masks, occupancy signals, reservations, rerouting and congestion escape are hand-written.
  3. 03
    Neural policy → movement or waitSupervised imitation of a yielding rule. The rule remains a comparison controller.
  4. 04
    Optional guard → final movement checkRejects unsafe commands independently. Its interventions are reported separately.